-
LinuxCNC: Mesa 5I25 For The Sherline Mill
Updating the Sherline’s LinuxCNC from 2.7.ancient to 2.8.1, which I did by the simple expedient of replacing the hard drive with an SSD from the heap and doing a clean installation, provided the opportunity of switching from the parallel port to a Mesa 5I25 FPGA card to put timing-critical step generation under hardware control.
I had flashed the card with Mesa’s Probotix PBX-RF BIT file, then invoked it with a configuration string turning off everything except the stepgen modules:
loadrt hm2_pci config="num_encoders=0 num_pwmgens=0 num_stepgens=4"
Which produces a simple pinout on the back panel DB-25 connector:
hm2_pci: loading Mesa AnyIO HostMot2 driver version 0.7
hm2_pci: discovered 5i25 at 0000:04:02.0
hm2/hm2_5i25.0: Low Level init 0.15
hm2/hm2_5i25.0: 34 I/O Pins used:
hm2/hm2_5i25.0:     IO Pin 000 (P3-01): IOPort
hm2/hm2_5i25.0:     IO Pin 001 (P3-14): IOPort
hm2/hm2_5i25.0:     IO Pin 002 (P3-02): StepGen #0, pin Step (Output)
hm2/hm2_5i25.0:     IO Pin 003 (P3-15): IOPort
hm2/hm2_5i25.0:     IO Pin 004 (P3-03): StepGen #0, pin Direction (Output)
hm2/hm2_5i25.0:     IO Pin 005 (P3-16): IOPort
hm2/hm2_5i25.0:     IO Pin 006 (P3-04): StepGen #1, pin Step (Output)
hm2/hm2_5i25.0:     IO Pin 007 (P3-17): IOPort
hm2/hm2_5i25.0:     IO Pin 008 (P3-05): StepGen #1, pin Direction (Output)
hm2/hm2_5i25.0:     IO Pin 009 (P3-06): StepGen #2, pin Step (Output)
hm2/hm2_5i25.0:     IO Pin 010 (P3-07): StepGen #2, pin Direction (Output)
hm2/hm2_5i25.0:     IO Pin 011 (P3-08): StepGen #3, pin Step (Output)
hm2/hm2_5i25.0:     IO Pin 012 (P3-09): StepGen #3, pin Direction (Output)
hm2/hm2_5i25.0:     IO Pin 013 (P3-10): IOPort
hm2/hm2_5i25.0:     IO Pin 014 (P3-11): IOPort
hm2/hm2_5i25.0:     IO Pin 015 (P3-12): IOPort
hm2/hm2_5i25.0:     IO Pin 016 (P3-13): IOPort
The Sherline CNC driver requires an adapter to swap the Step and Direction signals on the output connector.
The Sherline controller expects active-low Step signals:
# invert step output bits
setp   [HMOT](FPGA0).gpio.002.invert_output     1
setp   [HMOT](FPGA0).gpio.006.invert_output     1
setp   [HMOT](FPGA0).gpio.009.invert_output     1
setp   [HMOT](FPGA0).gpio.011.invert_output     1
The Y and Z drivers needed the same Direction swap as before:
# invert direction output bits
setp   [HMOT](FPGA0).gpio.008.invert_output     1
setp   [HMOT](FPGA0).gpio.010.invert_output     1
Because the 5I25 uses 3.3 V logic with interface drivers to match the “parallel port” 5 V levels, it has different electrical characteristics than the parallel port built into the Dell Optiplex 760. Putting a 100 nF cap across the Probe input reduced, but did not eliminate, what looked like a nice 60 Hz signal on that long wire, so I added a firmware debouncer:
loadrt debounce cfg=2
addf debounce.0               servo-thread
setp debounce.0.delay 3

net probe-raw debounce.0.1.in [HMOT](FPGA0).gpio.003.in_not
net probe-in debounce.0.1.out
The additional 3 ms delay doesn’t amount to much distance, even were I to probe at the machine’s top 10 mm/s speed.
Although the seemingly identical Home switch input seemed stable, it got the same treatment:
net home-raw debounce.0.0.in [HMOT](FPGA0).gpio.013.in_not
net all-home debounce.0.0.out
The PID loops have a very simple setup, with P = 1000 and FF1 = 1, which seems entirely adequate without any attempt at tuning. The following errors seems to stay under 20 ppm, in the machine’s native inches, while cutting the standard Axis “splash G-Code” file with all the speeds cranked up to 24 in/min = 610 mm/min:
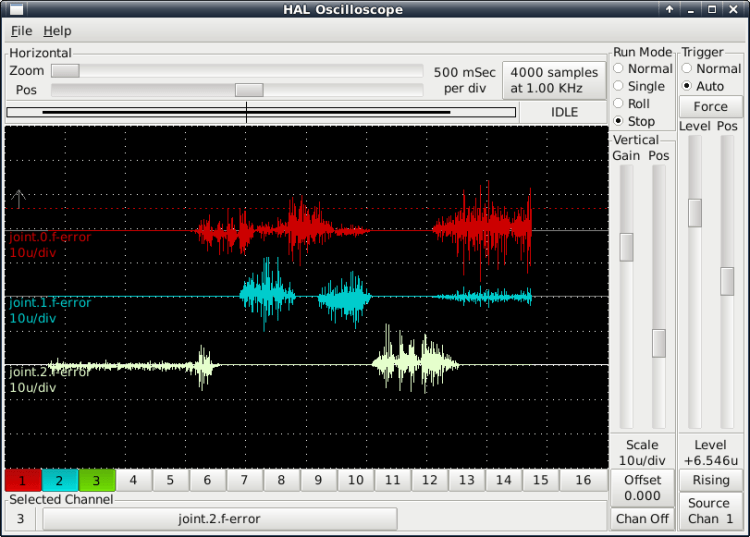
LinuxCNC – Sherline f-error Claiming a 20 µinch error for a Sherline is certainly aspirational.
The INI and HAL files as a GitHub Gist:
This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters. Learn more about bidirectional Unicode characters# DO NOT RUN PNCCONF EVER AGAIN loadrt [KINS]KINEMATICS loadrt [EMCMOT]EMCMOT servo_period_nsec=[EMCMOT]SERVO_PERIOD num_joints=[KINS]JOINTS loadrt hostmot2 loadrt hm2_pci config="num_encoders=0 num_pwmgens=0 num_stepgens=4" loadrt debounce cfg=2 addf debounce.0 servo-thread setp debounce.0.delay 3 setp [HMOT](FPGA0).watchdog.timeout_ns 5000000 loadrt pid names=pid.x,pid.y,pid.z,pid.a addf [HMOT](FPGA0).read servo-thread addf motion-command-handler servo-thread addf motion-controller servo-thread addf pid.x.do-pid-calcs servo-thread addf pid.y.do-pid-calcs servo-thread addf pid.z.do-pid-calcs servo-thread addf pid.a.do-pid-calcs servo-thread addf [HMOT](FPGA0).write servo-thread # external output signals #setp [HMOT](FPGA0).gpio.000.out 1 net estop-out [HMOT](FPGA0).gpio.000.out #net all-amps-enabled logic.0.and [HMOT](FPGA0).gpio.007.out # Home switch net home-raw debounce.0.0.in [HMOT](FPGA0).gpio.013.in_not net all-home debounce.0.0.out # Probe switch net probe-raw debounce.0.1.in [HMOT](FPGA0).gpio.003.in_not net probe-in debounce.0.1.out #******************* # AXIS X JOINT 0 #******************* setp pid.x.Pgain [JOINT_0]P setp pid.x.Igain [JOINT_0]I setp pid.x.Dgain [JOINT_0]D setp pid.x.bias [JOINT_0]BIAS setp pid.x.FF0 [JOINT_0]FF0 setp pid.x.FF1 [JOINT_0]FF1 setp pid.x.FF2 [JOINT_0]FF2 setp pid.x.deadband [JOINT_0]DEADBAND setp pid.x.maxoutput [JOINT_0]MAX_OUTPUT setp pid.x.error-previous-target true # This setting is to limit bogus stepgen # velocity corrections caused by position # feedback sample time jitter. setp pid.x.maxerror 0.000500 net x-index-enable <=> pid.x.index-enable net x-amp-enable => pid.x.enable net x-pos-cmd => pid.x.command net x-pos-fb => pid.x.feedback net x-output <= pid.x.output # Step Gen signals/setup setp [HMOT](FPGA0).stepgen.00.dirsetup [JOINT_0]DIRSETUP setp [HMOT](FPGA0).stepgen.00.dirhold [JOINT_0]DIRHOLD setp [HMOT](FPGA0).stepgen.00.steplen [JOINT_0]STEPLEN setp [HMOT](FPGA0).stepgen.00.stepspace [JOINT_0]STEPSPACE setp [HMOT](FPGA0).stepgen.00.position-scale [JOINT_0]STEP_SCALE setp [HMOT](FPGA0).stepgen.00.step_type 0 setp [HMOT](FPGA0).stepgen.00.control-type 1 setp [HMOT](FPGA0).stepgen.00.maxaccel [JOINT_0]STEPGEN_MAXACCEL setp [HMOT](FPGA0).stepgen.00.maxvel [JOINT_0]STEPGEN_MAXVEL # invert step output bit setp [HMOT](FPGA0).gpio.002.invert_output 1 # —closedloop stepper signals— net x-pos-cmd <= joint.0.motor-pos-cmd net x-vel-cmd <= joint.0.vel-cmd net x-output <= [HMOT](FPGA0).stepgen.00.velocity-cmd net x-pos-fb <= [HMOT](FPGA0).stepgen.00.position-fb net x-pos-fb => joint.0.motor-pos-fb net x-amp-enable <= joint.0.amp-enable-out net x-amp-enable => [HMOT](FPGA0).stepgen.00.enable # —setup home / limit switch signals— net all-home => joint.0.home-sw-in net x-neg-limit => joint.0.neg-lim-sw-in net x-pos-limit => joint.0.pos-lim-sw-in #******************* # AXIS Y JOINT 1 #******************* setp pid.y.Pgain [JOINT_1]P setp pid.y.Igain [JOINT_1]I setp pid.y.Dgain [JOINT_1]D setp pid.y.bias [JOINT_1]BIAS setp pid.y.FF0 [JOINT_1]FF0 setp pid.y.FF1 [JOINT_1]FF1 setp pid.y.FF2 [JOINT_1]FF2 setp pid.y.deadband [JOINT_1]DEADBAND setp pid.y.maxoutput [JOINT_1]MAX_OUTPUT setp pid.y.error-previous-target true # This setting is to limit bogus stepgen # velocity corrections caused by position # feedback sample time jitter. setp pid.y.maxerror 0.000500 net y-index-enable <=> pid.y.index-enable net y-amp-enable => pid.y.enable net y-pos-cmd => pid.y.command net y-pos-fb => pid.y.feedback net y-output <= pid.y.output # Step Gen signals/setup setp [HMOT](FPGA0).stepgen.01.dirsetup [JOINT_1]DIRSETUP setp [HMOT](FPGA0).stepgen.01.dirhold [JOINT_1]DIRHOLD setp [HMOT](FPGA0).stepgen.01.steplen [JOINT_1]STEPLEN setp [HMOT](FPGA0).stepgen.01.stepspace [JOINT_1]STEPSPACE setp [HMOT](FPGA0).stepgen.01.position-scale [JOINT_1]STEP_SCALE setp [HMOT](FPGA0).stepgen.01.step_type 0 setp [HMOT](FPGA0).stepgen.01.control-type 1 setp [HMOT](FPGA0).stepgen.01.maxaccel [JOINT_1]STEPGEN_MAXACCEL setp [HMOT](FPGA0).stepgen.01.maxvel [JOINT_1]STEPGEN_MAXVEL # invert step output bit setp [HMOT](FPGA0).gpio.006.invert_output 1 # invert direction output bit setp [HMOT](FPGA0).gpio.008.invert_output 1 # —closedloop stepper signals— net y-pos-cmd <= joint.1.motor-pos-cmd net y-vel-cmd <= joint.1.vel-cmd net y-output <= [HMOT](FPGA0).stepgen.01.velocity-cmd net y-pos-fb <= [HMOT](FPGA0).stepgen.01.position-fb net y-pos-fb => joint.1.motor-pos-fb net y-amp-enable <= joint.1.amp-enable-out net y-amp-enable => [HMOT](FPGA0).stepgen.01.enable # —setup home / limit switch signals— net all-home => joint.1.home-sw-in net y-neg-limit => joint.1.neg-lim-sw-in net y-pos-limit => joint.1.pos-lim-sw-in #******************* # AXIS Z JOINT 2 #******************* setp pid.z.Pgain [JOINT_2]P setp pid.z.Igain [JOINT_2]I setp pid.z.Dgain [JOINT_2]D setp pid.z.bias [JOINT_2]BIAS setp pid.z.FF0 [JOINT_2]FF0 setp pid.z.FF1 [JOINT_2]FF1 setp pid.z.FF2 [JOINT_2]FF2 setp pid.z.deadband [JOINT_2]DEADBAND setp pid.z.maxoutput [JOINT_2]MAX_OUTPUT setp pid.z.error-previous-target true # This setting is to limit bogus stepgen # velocity corrections caused by position # feedback sample time jitter. setp pid.z.maxerror 0.000500 net z-index-enable <=> pid.z.index-enable net z-amp-enable => pid.z.enable net z-pos-cmd => pid.z.command net z-pos-fb => pid.z.feedback net z-output <= pid.z.output # Step Gen signals/setup setp [HMOT](FPGA0).stepgen.02.dirsetup [JOINT_2]DIRSETUP setp [HMOT](FPGA0).stepgen.02.dirhold [JOINT_2]DIRHOLD setp [HMOT](FPGA0).stepgen.02.steplen [JOINT_2]STEPLEN setp [HMOT](FPGA0).stepgen.02.stepspace [JOINT_2]STEPSPACE setp [HMOT](FPGA0).stepgen.02.position-scale [JOINT_2]STEP_SCALE setp [HMOT](FPGA0).stepgen.02.step_type 0 setp [HMOT](FPGA0).stepgen.02.control-type 1 setp [HMOT](FPGA0).stepgen.02.maxaccel [JOINT_2]STEPGEN_MAXACCEL setp [HMOT](FPGA0).stepgen.02.maxvel [JOINT_2]STEPGEN_MAXVEL # invert step output bit setp [HMOT](FPGA0).gpio.009.invert_output 1 # invert direction output bit setp [HMOT](FPGA0).gpio.010.invert_output 1 # —closedloop stepper signals— net z-pos-cmd <= joint.2.motor-pos-cmd net z-vel-cmd <= joint.2.vel-cmd net z-output <= [HMOT](FPGA0).stepgen.02.velocity-cmd net z-pos-fb <= [HMOT](FPGA0).stepgen.02.position-fb net z-pos-fb => joint.2.motor-pos-fb net z-amp-enable <= joint.2.amp-enable-out net z-amp-enable => [HMOT](FPGA0).stepgen.02.enable # —setup home / limit switch signals— net all-home => joint.2.home-sw-in net z-neg-limit => joint.2.neg-lim-sw-in net z-pos-limit => joint.2.pos-lim-sw-in #******************* # AXIS A JOINT 3 #******************* setp pid.a.Pgain [JOINT_3]P setp pid.a.Igain [JOINT_3]I setp pid.a.Dgain [JOINT_3]D setp pid.a.bias [JOINT_3]BIAS setp pid.a.FF0 [JOINT_3]FF0 setp pid.a.FF1 [JOINT_3]FF1 setp pid.a.FF2 [JOINT_3]FF2 setp pid.a.deadband [JOINT_3]DEADBAND setp pid.a.maxoutput [JOINT_3]MAX_OUTPUT setp pid.a.error-previous-target true # This setting is to limit bogus stepgen # velocity corrections caused by position # feedback sample time jitter. setp pid.a.maxerror 0.000500 net a-index-enable <=> pid.a.index-enable net a-amp-enable => pid.a.enable net a-pos-cmd => pid.a.command net a-pos-fb => pid.a.feedback net a-output <= pid.a.output # Step Gen signals/setup setp [HMOT](FPGA0).stepgen.03.dirsetup [JOINT_3]DIRSETUP setp [HMOT](FPGA0).stepgen.03.dirhold [JOINT_3]DIRHOLD setp [HMOT](FPGA0).stepgen.03.steplen [JOINT_3]STEPLEN setp [HMOT](FPGA0).stepgen.03.stepspace [JOINT_3]STEPSPACE setp [HMOT](FPGA0).stepgen.03.position-scale [JOINT_3]STEP_SCALE setp [HMOT](FPGA0).stepgen.03.step_type 0 setp [HMOT](FPGA0).stepgen.03.control-type 1 setp [HMOT](FPGA0).stepgen.03.maxaccel [JOINT_3]STEPGEN_MAXACCEL setp [HMOT](FPGA0).stepgen.03.maxvel [JOINT_3]STEPGEN_MAXVEL # invert step output bit setp [HMOT](FPGA0).gpio.011.invert_output 1 # —closedloop stepper signals— net a-pos-cmd <= joint.3.motor-pos-cmd net a-vel-cmd <= joint.3.vel-cmd net a-output <= [HMOT](FPGA0).stepgen.03.velocity-cmd net a-pos-fb <= [HMOT](FPGA0).stepgen.03.position-fb net a-pos-fb => joint.3.motor-pos-fb net a-amp-enable <= joint.3.amp-enable-out net a-amp-enable => [HMOT](FPGA0).stepgen.03.enable # —setup home / limit switch signals— net all-home => joint.3.home-sw-in net a-neg-limit => joint.3.neg-lim-sw-in net a-pos-limit => joint.3.pos-lim-sw-in #****************************** # connect miscellaneous signals #****************************** # —HALUI signals— net axis-select-x halui.axis.x.select net x-is-homed halui.joint.0.is-homed net axis-select-y halui.axis.y.select net y-is-homed halui.joint.1.is-homed net axis-select-z halui.axis.z.select net z-is-homed halui.joint.2.is-homed net axis-select-a halui.axis.a.select net a-is-homed halui.joint.3.is-homed net jog-selected-pos halui.axis.selected.plus net jog-selected-neg halui.axis.selected.minus net spindle-manual-cw halui.spindle.0.forward net spindle-manual-ccw halui.spindle.0.reverse net spindle-manual-stop halui.spindle.0.stop net MDI-mode halui.mode.is-mdi # —coolant signals— net coolant-mist <= iocontrol.0.coolant-mist net coolant-flood <= iocontrol.0.coolant-flood # —probe signal— net probe-in => motion.probe-input # —motion control signals— net in-position <= motion.in-position net machine-is-enabled <= motion.motion-enabled # —digital in / out signals— # —estop signals— net estop-out <= iocontrol.0.user-enable-out net estop-out => iocontrol.0.emc-enable-in # —manual tool change signals— loadusr -W hal_manualtoolchange net tool-change-request iocontrol.0.tool-change => hal_manualtoolchange.change net tool-change-confirmed iocontrol.0.tool-changed <= hal_manualtoolchange.changed net tool-number iocontrol.0.tool-prep-number => hal_manualtoolchange.number net tool-prepare-loopback iocontrol.0.tool-prepare => iocontrol.0.tool-prepared This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters. Learn more about bidirectional Unicode characters# DO NOT RUN PNCCONF EVER AGAIN [EMC] MACHINE = Razor-5i25 DEBUG = 0 VERSION = 1.1 [DISPLAY] DISPLAY = axis POSITION_OFFSET = RELATIVE POSITION_FEEDBACK = ACTUAL MAX_FEED_OVERRIDE = 2.000000 MAX_SPINDLE_OVERRIDE = 1.000000 MIN_SPINDLE_OVERRIDE = 0.500000 INTRO_GRAPHIC = /home/ed/linuxcnc/configs/razor-5i25/Sherline.gif INTRO_TIME = 3 PROGRAM_PREFIX = /mnt/bulkdata/ INCREMENTS = 50mm 10mm 1mm 0.1mm 90 45 10 5 1 GRIDS = 100mm 50mm 25mm 10mm 5mm POSITION_FEEDBACK = ACTUAL DEFAULT_LINEAR_VELOCITY = 0.200000 MAX_LINEAR_VELOCITY = 0.400000 MIN_LINEAR_VELOCITY = 0.016670 DEFAULT_ANGULAR_VELOCITY = 12.000000 MAX_ANGULAR_VELOCITY = 180.000000 MIN_ANGULAR_VELOCITY = 1.666667 EDITOR = gedit GEOMETRY = axyz [FILTER] PROGRAM_EXTENSION = .png,.gif,.jpg Greyscale Depth Image PROGRAM_EXTENSION = .py Python Script png = image-to-gcode gif = image-to-gcode jpg = image-to-gcode py = python [TASK] TASK = milltask CYCLE_TIME = 0.010 [RS274NGC] PARAMETER_FILE = linuxcnc.var RS274NGC_STARTUP_CODE = G21 G40 G49 G54 G80 G90 G92.1 G94 G97 G98 [EMCMOT] EMCMOT = motmod COMM_TIMEOUT = 1.0 SERVO_PERIOD = 1000000 [HMOT] FPGA0 = hm2_5i25.0 [HAL] TWOPASS = on HALUI = halui HALFILE = razor-5i25.hal #HALFILE = joggy.hal HALFILE = custom.hal POSTGUI_HALFILE = postgui_call_list.hal SHUTDOWN = shutdown.hal #HALFILE = LIB:halcheck.tcl [HALUI] [KINS] JOINTS = 4 KINEMATICS = trivkins coordinates=XYZA [TRAJ] COORDINATES = XYZA LINEAR_UNITS = inch ANGULAR_UNITS = degree DEFAULT_LINEAR_VELOCITY = 0.10 MAX_LINEAR_VELOCITY = 0.4 MAX_ANGULAR_VELOCITY = 45 DEFAULT_ANGULAR_VELOCITY = 25.00 NO_FORCE_HOMING = 1 POSITION_FILE = lastposition.txt [EMCIO] EMCIO = io CYCLE_TIME = 0.100 TOOL_TABLE = tool.tbl #****************************************** [AXIS_X] MIN_LIMIT = -1.0 MAX_LIMIT = 9.5 MAX_VELOCITY = 0.4 MAX_ACCELERATION = 5.0 [JOINT_0] TYPE = LINEAR FERROR = 0.01 MIN_FERROR = 0.001 MAX_VELOCITY = 0.4 MAX_ACCELERATION = 5.0 BACKLASH = 0.003 # The values below should be 25% larger than MAX_VELOCITY and MAX_ACCELERATION # If using BACKLASH compensation STEPGEN_MAXACCEL should be 100% larger. STEPGEN_MAXVEL = 0.6 STEPGEN_MAXACCEL = 20 P = 1000.0 I = 0.0 D = 0.0 FF0 = 0.0 FF1 = 1.0 FF2 = 0.0 BIAS = 0.0 DEADBAND = 0.0 MAX_OUTPUT = 0.0 # these are in nanoseconds DIRSETUP = 25000 DIRHOLD = 25000 STEPLEN = 25000 STEPSPACE = 25000 STEP_SCALE = 16000 MIN_LIMIT = -1.0 MAX_LIMIT = 9.5 HOME = 5.25 HOME_OFFSET = 9.1 HOME_SEARCH_VEL = 0.3 HOME_LATCH_VEL = 0.03 HOME_FINAL_VEL = 0.4 HOME_USE_INDEX = NO HOME_IS_SHARED = 1 HOME_SEQUENCE = 1 #****************************************** #****************************************** [AXIS_Y] MIN_LIMIT = 0.00 MAX_LIMIT = 5.10 MAX_VELOCITY = 0.4 MAX_ACCELERATION = 5.0 [JOINT_1] TYPE = LINEAR FERROR = 0.01 MIN_FERROR = 0.001 MAX_VELOCITY = 0.4 MAX_ACCELERATION = 5.0 BACKLASH = 0.003 # The values below should be 25% larger than MAX_VELOCITY and MAX_ACCELERATION # If using BACKLASH compensation STEPGEN_MAXACCEL should be 100% larger. STEPGEN_MAXVEL = 0.6 STEPGEN_MAXACCEL = 10.0 P = 1000.0 I = 0.0 D = 0.0 FF0 = 0.0 FF1 = 1.0 FF2 = 0.0 BIAS = 0.0 DEADBAND = 0.0 MAX_OUTPUT = 0.0 # these are in nanoseconds DIRSETUP = 25000 DIRHOLD = 25000 STEPLEN = 25000 STEPSPACE = 25000 STEP_SCALE = 16000 MIN_LIMIT = 0.0 MAX_LIMIT = 5.1 HOME = 4.5 HOME_OFFSET = 5.1 HOME_SEARCH_VEL = 0.3 HOME_LATCH_VEL = 0.03 HOME_FINAL_VEL = 0.4 HOME_USE_INDEX = NO HOME_IS_SHARED = 1 HOME_SEQUENCE = 2 #****************************************** #****************************************** [AXIS_Z] MIN_LIMIT = 0.0 MAX_LIMIT = 6.680 MAX_VELOCITY = 0.333 MAX_ACCELERATION = 3.0 [JOINT_2] TYPE = LINEAR FERROR = 0.01 MIN_FERROR = 0.001 MAX_VELOCITY = 0.333 MAX_ACCELERATION = 3.0 BACKLASH = 0.005 # The values below should be 25% larger than MAX_VELOCITY and MAX_ACCELERATION # If using BACKLASH compensation STEPGEN_MAXACCEL should be 100% larger. STEPGEN_MAXVEL = 0.6 STEPGEN_MAXACCEL = 6 P = 1000.0 I = 0.0 D = 0.0 FF0 = 0.0 FF1 = 1.0 FF2 = 0.0 BIAS = 0.0 DEADBAND = 0.0 MAX_OUTPUT = 0.0 # these are in nanoseconds DIRSETUP = 25000 DIRHOLD = 25000 STEPLEN = 25000 STEPSPACE = 25000 STEP_SCALE = 16000 MIN_LIMIT = 0.0 MAX_LIMIT = 6.68 HOME = 6.5 HOME_OFFSET = 6.68 HOME_SEARCH_VEL = 0.15 HOME_LATCH_VEL = 0.015 HOME_FINAL_VEL = 0.33 HOME_USE_INDEX = NO HOME_IS_SHARED = 1 HOME_SEQUENCE = 0 #****************************************** #****************************************** [AXIS_A] MIN_LIMIT = -9999999 MAX_LIMIT = 9999999 MAX_VELOCITY = 45.0 MAX_ACCELERATION = 250.0 [JOINT_3] TYPE = ANGULAR FERROR = 0.1 MIN_FERROR = 0.01 MAX_VELOCITY = 45.0 MAX_ACCELERATION = 250.0 # The values below should be 25% larger than MAX_VELOCITY and MAX_ACCELERATION # If using BACKLASH compensation STEPGEN_MAXACCEL should be 100% larger. STEPGEN_MAXVEL = 50 STEPGEN_MAXACCEL = 300 P = 1000.0 I = 0.0 D = 0.0 FF0 = 0.0 FF1 = 1.0 FF2 = 0.0 BIAS = 0.0 DEADBAND = 0.0 MAX_OUTPUT = 0.0 # these are in nanoseconds DIRSETUP = 25000 DIRHOLD = 25000 STEPLEN = 25000 STEPSPACE = 25000 STEP_SCALE = 160 MIN_LIMIT = -9999999 MAX_LIMIT = 9999999 HOME = 0.0 HOME_OFFSET = 0 HOME_SEARCH_VEL = 0 HOME_LATCH_VEL = 0 HOME_FINAL_VEL = 0 HOME_USE_INDEX = NO HOME_SEQUENCE = 3 #****************************************** Adapting the HAL code driving my Joggy Thing to its new home didn’t go quite as smoothly, about which, more later.
-
Subscribe
Subscribed
Have a WordPress.com account? Log in now.

