-
Kicad-to-HAL: Threads
The Kicad THREAD symbol (center bottom) creates the HAL
addfcommands connecting HAL component functions to the realtime threads: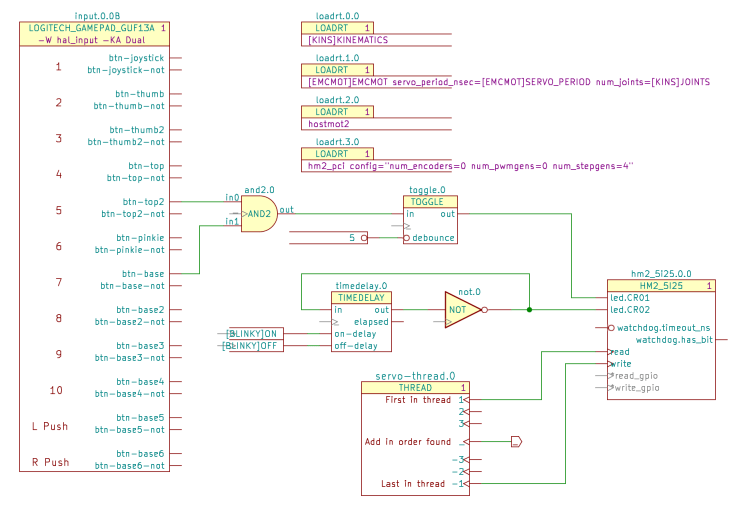
Kicad-to-HAL Demo Schematic Change the Kicad reference to match the HAL thread name. AFAICT, you can use either
servo-threadorbase-thread, as defined by theLoadRTconfiguration (center top).Opinion: contemporary x86-64 PC architecture pretty much prevents running a
base-threadat the pace required for step generation through a parallel port. In point of fact, I wrote Kicad-to-HAL specifically to configure a PC around a Mesa Electronics 5i25 FPGA controller for my Sherline CNC mill, as the real-time latency had regular glitches far exceeding the nominal 50 µs period. I suspect few new CNC installations will need a fast base thread.The THREAD symbol has seven “Power output” pins drawn in the Clock graphic style:
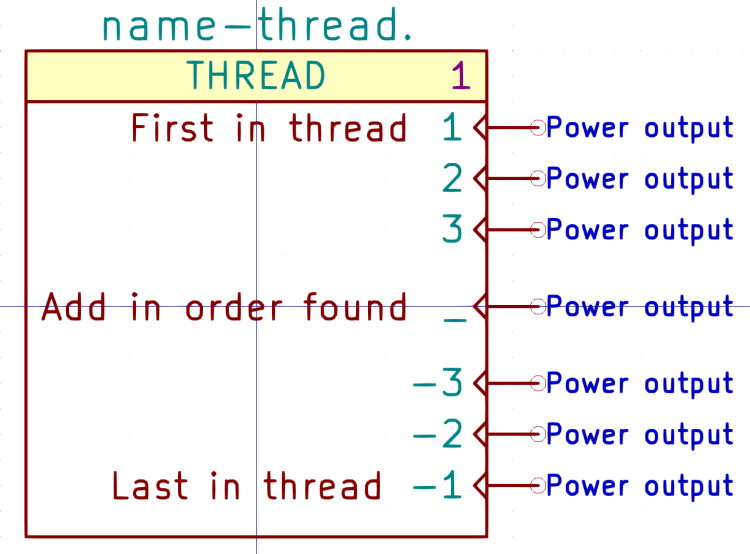
Kicad symbol – THREAD Kicad-to-HAL finds the other components attached to each pin and generates
addfcommands:#------ # Function hookups # Position: 1 addf hm2_5i25.0.read servo-thread # Position: _ addf and2.0 servo-thread addf constant.0 servo-thread addf constant.1 servo-thread addf not.0 servo-thread addf timedelay.0 servo-thread addf toggle.0 servo-thread # Position: -1 addf hm2_5i25.0.write servo-thread
FiXME: Contrary to the comment in the symbol,
addfcommands for each pin come out sorted by reference.The Mesa
hostmot2HAL component (middle right in the first screenshot) generates several function names that don’t require connections, but Kicad-to-HAL produces a warning for single-pin (i.e. unconnected) nets with non-default names. Prefix the pin name with an asterisk (*read-gpio) to suppress the error message.The
motionHAL component (lower right below) has functions that do not follow the normal naming convention: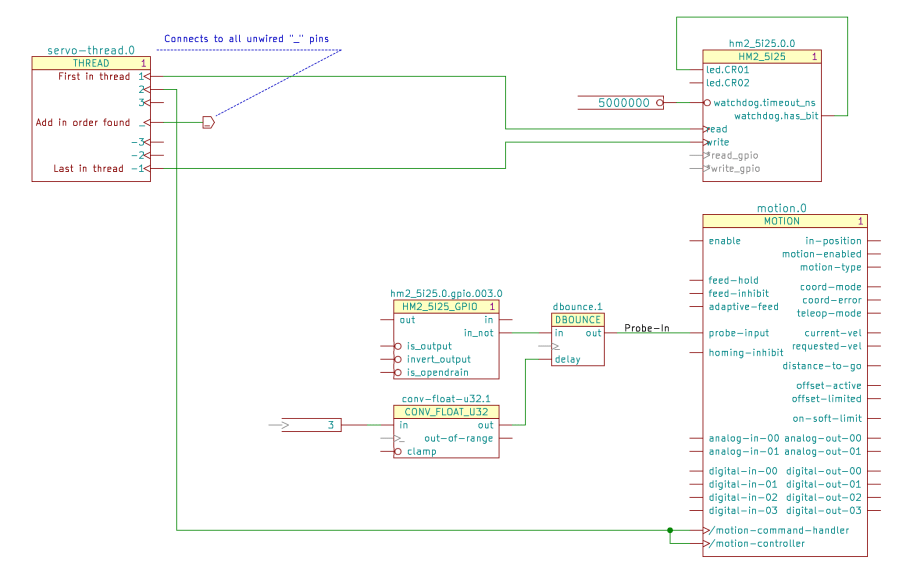
Servo Thread Hookup schematic Prefix the Kicad pin name with a slash (
/motion-controller) to tell Kicad-to-HAL to use the name without the standardmotion.prefix:# Position: 2 addf motion-command-handler servo-thread addf motion-controller servo-thread
Perhaps they were supposed to be
motion.command-handlerandmotion.controller, but it’s too late to change? If so, I know that feeling.Other quirks surely lurk within other HAL components, but, on the whole, this seems to work pretty well.
-
Subscribe
Subscribed
Have a WordPress.com account? Log in now.

