-
LinuxCNC 2.7 vs. Logitech Joggy Thing
The old Atom running LinuxCNC for the Sherline finally stopped booting, so I popped the Optiplex 760 off the stack and did a live-USB trial run. The latency / jitter worked out around 25 µs, slightly worse than before, but still Good Enough, and the StepConf utility coerced the motors into working OK.
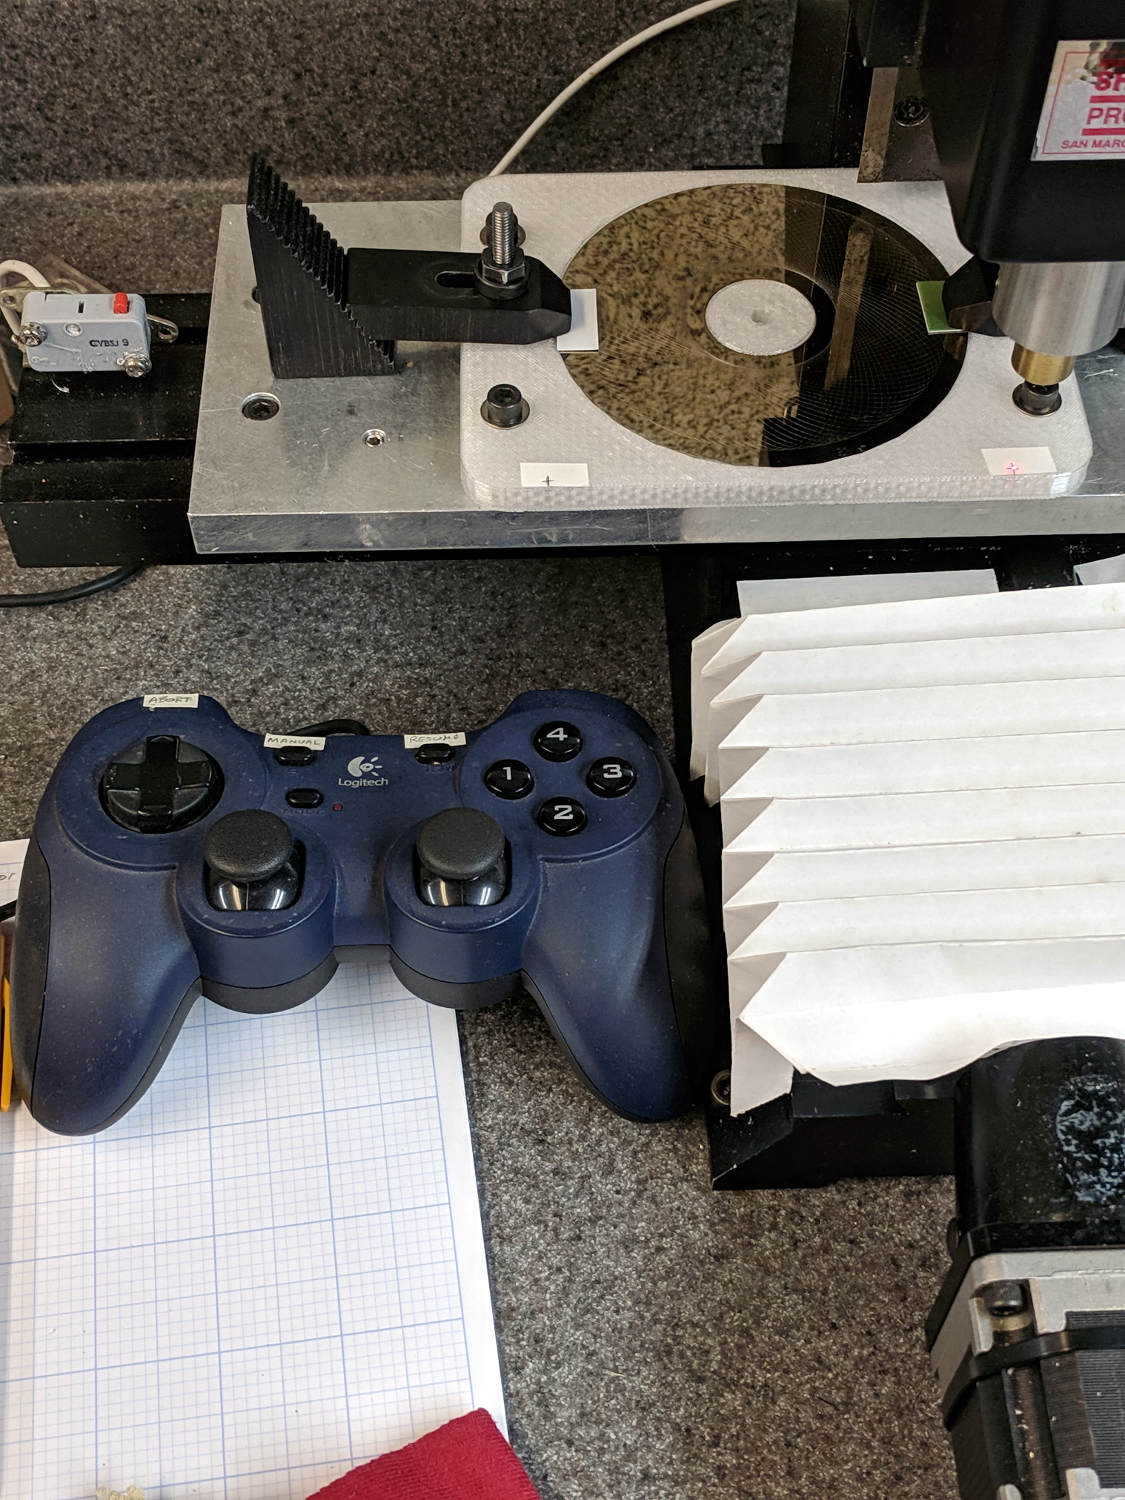
What didn’t work was the old Eagle-to-HAL code defining the Logitch Gamepad as a Joggy Thing to allow smooth joystick jog control. Well, stuff changes over the course of eight years, but, in this case, the fix turned out to be a one-liner: the
probe_parportmodule isn’t needed nowadays.With that out of the way, it runs fine:

LinuxCNC – Sherline Mill – Logitech Gamepad The INI and HAL files defining the Sherline configuration as a GitHub Gist:
This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters. Learn more about bidirectional Unicode characters# HAL config file automatically generated by Eagle-CAD ULP: # [/mnt/bulkdata/Project Files/eagle/ulp/hal-write-2.5.ulp] # (C) Martin Schoeneck.de 2008 # Charalampos Alexopoulos 2011 # Mods Ed Nisley KE4ZNU 2010 2013 # Path [/mnt/bulkdata/Project Files/eagle/projects/LinuxCNC for M2/] # ProjectName [LinuxCNC Sherline Configuration] # File name [/mnt/bulkdata/Project Files/eagle/projects/LinuxCNC for M2/LinuxCNC Sherline Configuration.hal] # Created [11:17:21 17-Feb-2013] #################################################### # Load realtime and userspace modules loadrt trivkins loadrt [EMCMOT]EMCMOT key=[EMCMOT]SHMEM_KEY num_joints=[TRAJ]AXES base_period_nsec=[EMCMOT]BASE_PERIOD servo_period_nsec=[EMCMOT]SERVO_PERIOD traj_period_nsec=[EMCMOT]SERVO_PERIOD # not needed in 2.7 # loadrt probe_parport loadrt hal_parport cfg="[PARPORT]ADDRESS out" loadrt stepgen step_type=0,0,0,0 loadrt pwmgen output_type=0 loadusr -W hal_manualtoolchange loadusr -W hal_input -KA Dual loadrt logic count=1 personality=0x104 loadrt constant count=13 loadrt and2 count=17 loadrt conv_float_s32 count=1 loadrt flipflop count=4 loadrt mux2 count=5 loadrt mux4 count=1 loadrt not count=8 loadrt or2 count=14 loadrt scale count=7 loadrt timedelay count=1 loadrt toggle count=1 #################################################### # Hook functions into threads addf stepgen.make-pulses base-thread addf pwmgen.make-pulses base-thread addf parport.0.read base-thread addf parport.0.write base-thread addf parport.0.reset base-thread addf logic.0 base-thread addf motion-command-handler servo-thread addf motion-controller servo-thread addf stepgen.update-freq servo-thread addf stepgen.capture-position servo-thread addf pwmgen.update servo-thread addf constant.0 servo-thread addf constant.1 servo-thread addf constant.2 servo-thread addf constant.3 servo-thread addf constant.4 servo-thread addf constant.5 servo-thread addf constant.6 servo-thread addf constant.7 servo-thread addf constant.8 servo-thread addf constant.9 servo-thread addf constant.10 servo-thread addf constant.11 servo-thread addf constant.12 servo-thread addf and2.0 servo-thread addf and2.1 servo-thread addf and2.2 servo-thread addf and2.3 servo-thread addf and2.4 servo-thread addf and2.5 servo-thread addf and2.6 servo-thread addf and2.7 servo-thread addf and2.8 servo-thread addf and2.9 servo-thread addf and2.10 servo-thread addf and2.11 servo-thread addf and2.12 servo-thread addf and2.13 servo-thread addf and2.14 servo-thread addf and2.15 servo-thread addf and2.16 servo-thread addf conv-float-s32.0 servo-thread addf toggle.0 servo-thread addf flipflop.0 servo-thread addf flipflop.1 servo-thread addf flipflop.2 servo-thread addf flipflop.3 servo-thread addf timedelay.0 servo-thread addf or2.0 servo-thread addf or2.1 servo-thread addf or2.2 servo-thread addf or2.3 servo-thread addf or2.4 servo-thread addf or2.5 servo-thread addf or2.6 servo-thread addf or2.7 servo-thread addf or2.8 servo-thread addf or2.9 servo-thread addf or2.10 servo-thread addf or2.11 servo-thread addf or2.12 servo-thread addf or2.13 servo-thread addf not.0 servo-thread addf not.1 servo-thread addf not.2 servo-thread addf not.3 servo-thread addf not.4 servo-thread addf not.5 servo-thread addf not.6 servo-thread addf not.7 servo-thread addf scale.0 servo-thread addf scale.1 servo-thread addf scale.2 servo-thread addf scale.3 servo-thread addf scale.4 servo-thread addf scale.5 servo-thread addf scale.6 servo-thread addf mux2.0 servo-thread addf mux4.0 servo-thread addf mux2.1 servo-thread addf mux2.2 servo-thread addf mux2.3 servo-thread addf mux2.4 servo-thread #################################################### # Set parameters setp parport.0.reset-time [PARPORT]RESET_TIME setp stepgen.0.maxaccel [AXIS_0]STEPGEN_MAXACCEL setp stepgen.0.maxvel [AXIS_0]MAX_VELOCITY setp stepgen.0.dirhold [PARPORT]DIRHOLD setp stepgen.0.dirsetup [PARPORT]DIRSETUP setp stepgen.0.steplen [PARPORT]STEPLEN setp stepgen.0.stepspace [PARPORT]STEPSPACE setp stepgen.0.position-scale [AXIS_0]SCALE setp parport.0.pin-03-out-reset FALSE setp parport.0.pin-05-out-reset FALSE setp parport.0.pin-07-out-reset FALSE setp parport.0.pin-09-out-reset FALSE setp parport.0.pin-17-out-reset FALSE setp stepgen.1.maxaccel [AXIS_1]STEPGEN_MAXACCEL setp stepgen.1.maxvel [AXIS_1]MAX_VELOCITY setp stepgen.1.dirhold [PARPORT]DIRHOLD setp stepgen.1.dirsetup [PARPORT]DIRSETUP setp stepgen.1.steplen [PARPORT]STEPLEN setp stepgen.1.stepspace [PARPORT]STEPSPACE setp stepgen.1.position-scale [AXIS_1]SCALE setp stepgen.2.maxaccel [AXIS_2]STEPGEN_MAXACCEL setp stepgen.2.maxvel [AXIS_2]MAX_VELOCITY setp stepgen.2.dirhold [PARPORT]DIRHOLD setp stepgen.2.dirsetup [PARPORT]DIRSETUP setp stepgen.2.steplen [PARPORT]STEPLEN setp stepgen.2.stepspace [PARPORT]STEPSPACE setp stepgen.2.position-scale [AXIS_2]SCALE setp stepgen.3.maxaccel [AXIS_3]STEPGEN_MAXACCEL setp stepgen.3.maxvel [AXIS_3]MAX_VELOCITY setp stepgen.3.dirhold [PARPORT]DIRHOLD setp stepgen.3.dirsetup [PARPORT]DIRSETUP setp stepgen.3.steplen [PARPORT]STEPLEN setp stepgen.3.stepspace [PARPORT]STEPSPACE setp stepgen.3.position-scale [AXIS_3]SCALE setp parport.0.pin-04-out-invert TRUE setp parport.0.pin-06-out-invert TRUE #################################################### # Set constants setp constant.0.value 0.1 setp constant.1.value 20 setp constant.2.value [TRAJ]MAX_LINEAR_VELOCITY setp constant.3.value [TRAJ]MAX_ANGULAR_VELOCITY setp constant.4.value 60 setp constant.5.value 0.50 setp constant.6.value 1.00 setp constant.7.value 0.10 setp constant.8.value 0.10 setp constant.9.value 0.0 setp constant.10.value -1.0 setp constant.11.value 0.020 setp constant.12.value 0.000 #################################################### # Connect Modules with nets net a-amp-enable logic.0.in-03 axis.3.amp-enable-out stepgen.3.enable net a-analog halui.jog.3.analog mux2.4.out net a-button-minus or2.0.in0 input.0.btn-joystick and2.7.in0 net a-button-plus or2.0.in1 input.0.btn-thumb2 and2.8.in0 net a-buttons-active or2.0.out or2.1.in0 or2.11.in1 net a-direction parport.0.pin-08-out stepgen.3.dir net a-disable not.7.out and2.13.in1 net a-enable or2.11.in0 flipflop.3.out not.7.in mux2.4.sel net a-jog input.0.abs-z-position mux2.4.in1 net a-knob-active or2.9.out not.2.in and2.15.in1 net a-knob-inactive not.2.out and2.14.in1 net a-select and2.16.in0 and2.15.out net a-set flipflop.3.set and2.16.out net a-step parport.0.pin-09-out stepgen.3.step net all-amps-enabled logic.0.and parport.0.pin-17-out net angular_motion or2.11.out mux2.0.sel net any-buttons-active mux4.0.sel0 or2.12.out net axis-disabled-value constant.9.out mux2.1.in0 mux2.2.in0 mux2.3.in0 mux2.4.in0 net az-buttons-active or2.1.out or2.12.in1 or2.13.in0 net az-reset flipflop.2.reset and2.14.out flipflop.3.reset net button-crawl scale.4.out mux4.0.in3 net button-fast scale.2.out mux4.0.in1 scale.4.in net estop-a and2.0.in0 input.0.btn-top2 net estop-b and2.0.in1 input.0.btn-base net estop-out parport.0.pin-01-out iocontrol.0.emc-enable-in iocontrol.0.user-enable-out net homeswitches parport.0.pin-10-in-not axis.0.home-sw-in axis.1.home-sw-in axis.2.home-sw-in axis.3.home-sw-in net jog-crawl toggle.0.out mux4.0.sel1 net jog-speed halui.jog-speed mux4.0.out net knob-crawl mux4.0.in2 scale.3.out net knob-fast mux4.0.in0 scale.1.out scale.3.in net manual-mode halui.mode.manual input.0.btn-base3 net n_9 axis.0.motor-pos-cmd stepgen.0.position-cmd net n_11 axis.0.motor-pos-fb stepgen.0.position-fb net n_13 and2.0.out halui.estop.activate net n_14 or2.3.in0 input.0.btn-base5 net n_15 or2.3.in1 input.0.btn-base6 net n_16 toggle.0.in or2.3.out net n_17 conv-float-s32.0.out input.0.abs-x-flat input.0.abs-y-flat input.0.abs-z-flat input.0.abs-rz-flat net n_18 constant.1.out conv-float-s32.0.in net n_19 constant.4.out scale.0.gain net n_20 constant.5.out scale.1.gain net n_21 constant.6.out scale.2.gain net n_22 constant.7.out scale.3.gain net n_23 scale.4.gain constant.8.out net n_24 constant.0.out halui.jog-deadband net n_25 constant.2.out mux2.0.in0 net n_26 mux2.0.in1 constant.3.out net n_34 axis.1.motor-pos-cmd stepgen.1.position-cmd net n_36 axis.1.motor-pos-fb stepgen.1.position-fb net n_42 or2.7.in0 input.0.abs-x-is-pos net n_43 or2.7.in1 input.0.abs-x-is-neg net n_44 or2.8.in0 input.0.abs-y-is-pos net n_45 or2.8.in1 input.0.abs-y-is-neg net n_46 or2.9.in0 input.0.abs-z-is-pos net n_47 or2.9.in1 input.0.abs-z-is-neg net n_48 or2.10.in0 input.0.abs-rz-is-pos net n_49 or2.10.in1 input.0.abs-rz-is-neg net n_51 constant.10.out scale.5.gain scale.6.gain net n_54 constant.11.out timedelay.0.on-delay net n_55 constant.12.out timedelay.0.off-delay net n_56 timedelay.0.out and2.1.in1 and2.2.in1 and2.4.in1 and2.3.in1 and2.5.in1 and2.6.in1 and2.8.in1 and2.7.in1 net n_57 and2.1.out halui.jog.0.minus net n_58 and2.2.out halui.jog.0.plus net n_59 and2.3.out halui.jog.1.minus net n_60 halui.jog.1.plus and2.4.out net n_61 and2.5.out halui.jog.2.minus net n_62 and2.6.out halui.jog.2.plus net n_63 and2.7.out halui.jog.3.minus net n_64 and2.8.out halui.jog.3.plus net n_67 axis.2.motor-pos-cmd stepgen.2.position-cmd net n_69 axis.2.motor-pos-fb stepgen.2.position-fb net n_77 axis.3.motor-pos-cmd stepgen.3.position-cmd net n_79 axis.3.motor-pos-fb stepgen.3.position-fb net probe-in parport.0.pin-15-in-not motion.probe-input net program-resume halui.program.resume input.0.btn-base4 net reset-estop input.0.btn-base2 halui.estop.reset net tool-change iocontrol.0.tool-change hal_manualtoolchange.change net tool-changed hal_manualtoolchange.changed iocontrol.0.tool-changed net tool-number iocontrol.0.tool-prep-number hal_manualtoolchange.number net tool-prepare-loopback iocontrol.0.tool-prepare iocontrol.0.tool-prepared net vel-per-minute scale.0.out scale.1.in scale.2.in net vel-per-second mux2.0.out scale.0.in net x-amp-enable logic.0.in-00 axis.0.amp-enable-out stepgen.0.enable net x-analog mux2.1.out halui.jog.0.analog net x-buttons-active or2.5.in0 or2.4.out net x-direction parport.0.pin-02-out stepgen.0.dir net x-disable not.4.out and2.12.in1 net x-enable not.4.in flipflop.0.out mux2.1.sel net x-hat-minus or2.4.in1 input.0.abs-hat0x-is-neg and2.1.in0 net x-hat-plus or2.4.in0 input.0.abs-hat0x-is-pos and2.2.in0 net x-jog input.0.abs-x-position mux2.1.in1 net x-knob-active or2.7.out not.0.in and2.9.in0 net x-knob-inactive not.0.out and2.10.in0 and2.11.in0 net x-set and2.9.out flipflop.0.set net x-step parport.0.pin-03-out stepgen.0.step net xy-buttons-active or2.5.out or2.12.in0 or2.13.in1 net xy-reset flipflop.0.reset and2.10.out flipflop.1.reset net xyza-buttons-active or2.13.out timedelay.0.in net y-amp-enable logic.0.in-01 axis.1.amp-enable-out stepgen.1.enable net y-analog halui.jog.1.analog mux2.2.out net y-buttons-active or2.6.out or2.5.in1 net y-direction parport.0.pin-04-out stepgen.1.dir net y-disable not.5.out and2.9.in1 net y-enable flipflop.1.out not.5.in mux2.2.sel net y-hat-minus or2.6.in1 input.0.abs-hat0y-is-neg and2.4.in0 net y-hat-plus or2.6.in0 input.0.abs-hat0y-is-pos and2.3.in0 net y-jog input.0.abs-y-position scale.5.in net y-jog-reversed mux2.2.in1 scale.5.out net y-knob-active not.1.in or2.8.out and2.11.in1 net y-knob-inactive not.1.out and2.10.in1 net y-select and2.12.in0 and2.11.out net y-set flipflop.1.set and2.12.out net y-step parport.0.pin-05-out stepgen.1.step net z-amp-enable logic.0.in-02 axis.2.amp-enable-out stepgen.2.enable net z-analog mux2.3.out halui.jog.2.analog net z-button-minus or2.2.in0 input.0.btn-thumb and2.5.in0 net z-button-plus or2.2.in1 input.0.btn-top and2.6.in0 net z-buttons-active or2.2.out or2.1.in1 net z-direction parport.0.pin-06-out stepgen.2.dir net z-disable not.6.out and2.16.in1 net z-enable not.6.in flipflop.2.out mux2.3.sel net z-jog input.0.abs-rz-position scale.6.in net z-jog-reversed scale.6.out mux2.3.in1 net z-knob-active not.3.in or2.10.out and2.13.in0 net z-knob-inactive not.3.out and2.15.in0 and2.14.in0 net z-set and2.13.out flipflop.2.set net z-step parport.0.pin-07-out stepgen.2.step This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters. Learn more about bidirectional Unicode characters# Ed Nisley – KE4ZNU # Just do not run stepconf ever again… [EMC] MACHINE = Sherline-XYZA DEBUG = 0 RS274NGC_STARTUP_CODE = G21 G40 G49 G54 G80 G90 G92.1 G94 G97 G98 [DISPLAY] DISPLAY = axis EDITOR = gedit GEOMETRY = AXYZ POSITION_OFFSET = RELATIVE POSITION_FEEDBACK = ACTUAL MAX_FEED_OVERRIDE = 3.0 INTRO_GRAPHIC = /home/ed/linuxcnc/configs/Sherline-XYZA/Sherline.gif INTRO_TIME = 3 PROGRAM_PREFIX = /mnt/bulkdata/ #PROGRAM_PREFIX = /home/ed/linuxcnc/nc_files/ #INCREMENTS = .1in .05in .01in .005in .001in .0005in .0001in INCREMENTS = 10 mm, 1 mm, 0.1 mm, 90 deg, 45 deg, 10 deg [FILTER] PROGRAM_EXTENSION = .py Python Script py = python [TASK] TASK = milltask CYCLE_TIME = 0.010 [RS274NGC] PARAMETER_FILE = emc.var [EMCMOT] EMCMOT = motmod SHMEM_KEY = 111 COMM_TIMEOUT = 1.0 COMM_WAIT = 0.010 BASE_PERIOD = 50000 SERVO_PERIOD = 1000000 [PARPORT] ADDRESS = 0x378 RESET_TIME = 10000 STEPLEN = 25000 STEPSPACE = 25000 DIRSETUP = 50000 DIRHOLD = 50000 [HAL] HALUI = halui HALFILE = Sherline.hal HALFILE = custom.hal POSTGUI_HALFILE = custom_postgui.hal [TRAJ] AXES = 4 COORDINATES = X Y Z A MAX_ANGULAR_VELOCITY = 45.00 DEFAULT_ANGULAR_VELOCITY = 36.0 LINEAR_UNITS = inch ANGULAR_UNITS = degree CYCLE_TIME = 0.010 DEFAULT_VELOCITY = 0.400 MAX_LINEAR_VELOCITY = 0.400 POSITION_FILE = lastposition.txt NO_FORCE_HOMING = 1 [EMCIO] EMCIO = io CYCLE_TIME = 0.100 TOOL_TABLE = Sherline.tbl TOOL_CHANGE_AT_G30 = 1 [AXIS_0] TYPE = LINEAR MAX_VELOCITY = 0.400 MAX_ACCELERATION = 5.0 STEPGEN_MAXACCEL = 10.0 SCALE = 16000.0 FERROR = 0.05 MIN_FERROR = 0.01 MIN_LIMIT = -1.0 MAX_LIMIT = 9.5 BACKLASH = 0.003 HOME_IS_SHARED = 1 HOME_SEQUENCE = 1 HOME_SEARCH_VEL = 0.3 HOME_LATCH_VEL = 0.03 HOME_FINAL_VEL = 0.4 HOME_OFFSET = 9.1 HOME = 5.25 [AXIS_1] TYPE = LINEAR MAX_VELOCITY = 0.400 MAX_ACCELERATION = 5.0 STEPGEN_MAXACCEL = 10.0 SCALE = 16000.0 FERROR = 0.05 MIN_FERROR = 0.01 MIN_LIMIT = 0.00 MAX_LIMIT = 5.10 BACKLASH = 0.003 HOME_IS_SHARED = 1 HOME_SEQUENCE = 2 HOME_SEARCH_VEL = 0.3 HOME_LATCH_VEL = 0.03 HOME_FINAL_VEL = 0.4 HOME_OFFSET = 5.1 HOME = 4.5 [AXIS_2] TYPE = LINEAR MAX_VELOCITY = 0.333 MAX_ACCELERATION = 3.0 STEPGEN_MAXACCEL = 6.0 SCALE = 16000.0 FERROR = 0.05 MIN_FERROR = 0.01 MIN_LIMIT = 0.0 MAX_LIMIT = 6.680 BACKLASH = 0.005 HOME_IS_SHARED = 1 HOME_SEQUENCE = 0 HOME_SEARCH_VEL = 0.150 HOME_LATCH_VEL = 0.015 HOME_FINAL_VEL = 0.33 HOME_OFFSET = 6.680 HOME = 6.500 [AXIS_3] TYPE = ANGULAR ###WRAPPED_ROTARY = 1 MAX_VELOCITY = 40.0 MAX_ACCELERATION = 250.0 STEPGEN_MAXACCEL = 275.0 SCALE = 160.0 FERROR = 1 MIN_FERROR = .25 MIN_LIMIT = -999999999.9 MAX_LIMIT = 999999999.9 HOME_SEARCH_VEL = 0 HOME_LATCH_VEL = 0 HOME = 0.0
-
Subscribe
Subscribed
Have a WordPress.com account? Log in now.

