-
CNC 3018-Pro: Probe Camera Case for Logitch QuickCam Pro 5000
The ball-shaped Logitch QuickCam Pro 5000 has a rectangular PCB, so conjuring a case wasn’t too challenging:

Probe Camera Case – Logitech QuickCam Pro 5000 – bottom That’s more-or-less matte black duct tape to cut down reflections.
The top side has a cover made from scuffed acrylic scrap:
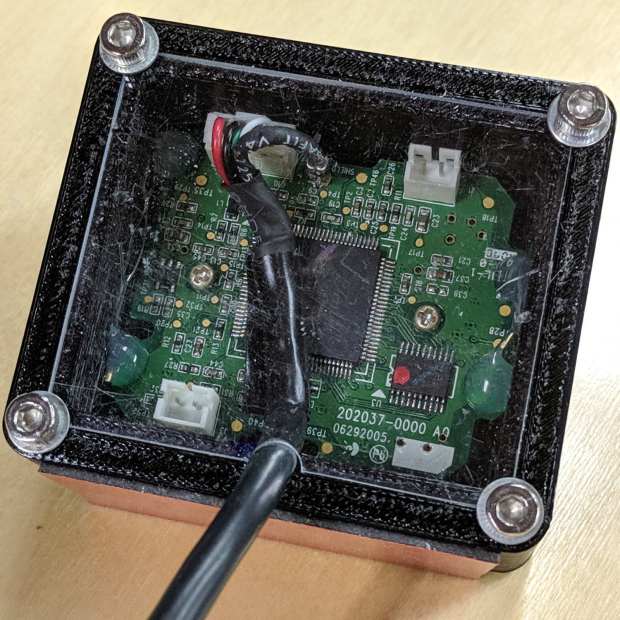
Probe Camera Case – Logitech QuickCam Pro 5000 – top The corners are slightly rounded to fit under the screw heads holding it in place.
The solid model shows off the internal ledge positioning the PCB so the camera lens housing rests on the floor:
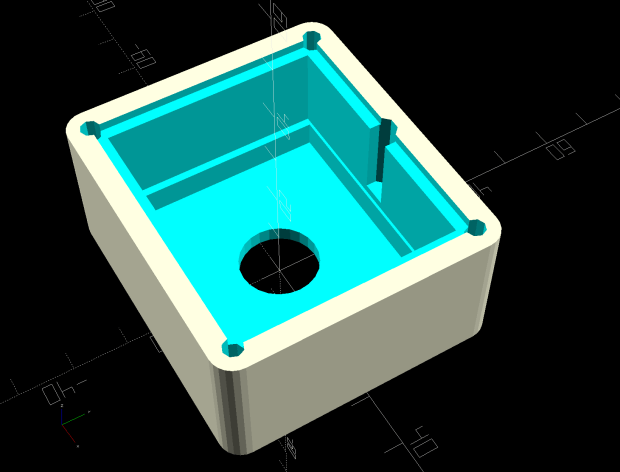
3018 Probe Camera Mount – solid model The notch lets the cable out, while keeping it in one place and providing some strain relief.
I though if a camera was recognized by V4L2 and worked with VLC, it was good to go:
Logitech QuickCam Pro 5000 – short focus Regrettably, it turns out the camera has a pixel format incompatible with the Python opencv interface used by bCNC. This may have something to do with running the code on a Raspberry Pi, rather than an x86 box.
The camera will surely come in handy for something else, especially with such a cute case.
The OpenSCAD source code as a GitHub Gist:
This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters. Learn more about bidirectional Unicode characters// Probe Camera Mount for CNC 3018-Pro Z Axis // Ed Nisley – KE4ZNU – 2019-08 Layout = "Block"; // [Show,Build,Block] Support = false; /* [Hidden] */ ThreadThick = 0.20; ThreadWidth = 0.40; HoleWindage = 0.2; Protrusion = 0.1; // make holes end cleanly function IntegerMultiple(Size,Unit) = Unit * ceil(Size / Unit); ID = 0; OD = 1; LENGTH = 2; inch = 25.4; //———————- // Dimensions PCB = [45.0,38.0,1.5]; // Logitech QuickCam Pro 5000 ball camera PCBLip = 1.0; // max non-component border PCBChamfer = 3.0; // cut along XY axes for corner bevel PCBClearTop = 15.0; // cables & connectors PCBClearSides = [0.5,0.5]; // irregular edges & comfort zone PCBClearBelow = 5.0; // lens support bracket rests on floor Lens = [11.5,14.2,3.0]; // LENGTH = beyond PCBClearBelow bracket LensOffset = [-1.5,0.0,0]; // distance from center of board CableOD = 4.5; BaseThick = Lens[LENGTH]; Screw = [ 3.0,6.8,18.0 // M3 OD=washer, LENGTH=below head ]; RoundRadius = IntegerMultiple(Screw[OD]/2,1.0); // corner rounding ScrewOC = [PCB.x + 2*sqrt(Screw[OD]),PCB.y + 2*sqrt(Screw[OD])]; echo(str("Screw OC: ",ScrewOC)); Lid = [ScrewOC.x,ScrewOC.y,1.0/16.0 * inch]; // top cover plate echo(str("Lid: ",Lid)); BlockSize = [ScrewOC.x + 2*RoundRadius,ScrewOC.y + 2*RoundRadius, BaseThick + PCBClearBelow + PCB.z + PCBClearTop + Lid.z]; echo(str("Block: ",BlockSize)); NumSides = 2*3*4; //———————- // Useful routines module PolyCyl(Dia,Height,ForceSides=0) { // based on nophead's polyholes Sides = (ForceSides != 0) ? ForceSides : (ceil(Dia) + 2); FixDia = Dia / cos(180/Sides); cylinder(r=(FixDia + HoleWindage)/2, h=Height, $fn=Sides); } // Basic shapes // Overall block module Block() { difference() { hull() for (i=[-1,1], j=[-1,1]) translate([i*ScrewOC.x/2,j*ScrewOC.y/2,0]) cylinder(r=RoundRadius,h=BlockSize.z,$fn=NumSides); for (i=[-1,1], j=[-1,1]) // corner screws translate([i*ScrewOC.x/2,j*ScrewOC.y/2,BlockSize.z – Screw[LENGTH]]) cylinder(d=Screw[ID],h=2*Screw[LENGTH],$fn=8); // cylinder = undersized translate(LensOffset + [0,0,-Protrusion]) // lens body PolyCyl(Lens[OD],2*BlockSize.z,NumSides); translate([0,0,BlockSize.z/2 + BaseThick]) // PCB lip on bottom cube([PCB.x – 2*PCBLip,PCB.y,BlockSize.z],center=true); translate([0,0,BlockSize.z/2 + BaseThick + PCBClearBelow]) // PCB clearance cube([PCB.x + 2*PCBClearSides.x,PCB.y + 2*PCBClearSides.y,BlockSize.z],center=true); translate([0,0,BlockSize.z – Lid.z/2]) // lid recess cube(Lid + [0,0,Protrusion],center=true); translate([0,Lid.y/2 – CableOD/2,BaseThick + PCBClearBelow + PCB.z]) // cable exit hull() for (j=[-1,1]) translate([0,j*CableOD/4,0]) rotate(180/8) PolyCyl(CableOD,BlockSize.z,8); } } //- Build it if (Layout == "Block") Block(); if (Layout == "Show") { Block(); } if (Layout == "Build") { Block(); }
-
Subscribe
Subscribed
Have a WordPress.com account? Log in now.

