-
Nissan Fog Lamp: Desk Stand
The Nissan fog lamp looks pretty good pointing at the ceiling:

Nissan Fog Lamp – table mount I briefly considered sandblasting the shell to knock back the corrosion, but came to my senses: this is art!
The shell has a bayonet mount intended for the cable connector, but a bout of solid modeling produced a matching twist-lock desk stand:
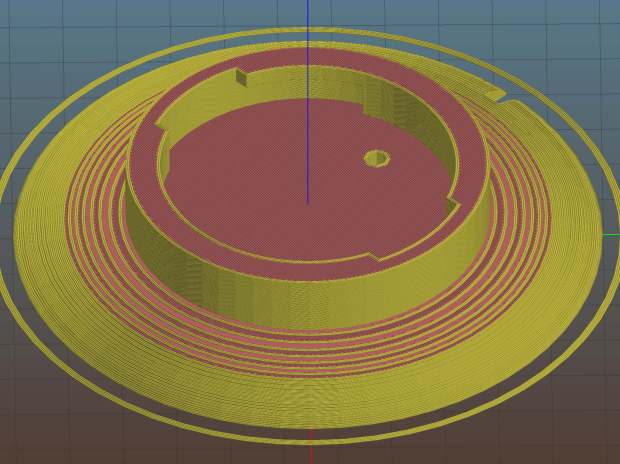
Nissan Fog Light Base – Slic3r preview The locking dogs overhang little enough, relative to their diameter, to let the thing build without internal supports. Took about three hours without any intervention at all.
The little hole matches up with the slot on the bottom holding a USB cable bringing power from a wall charger:
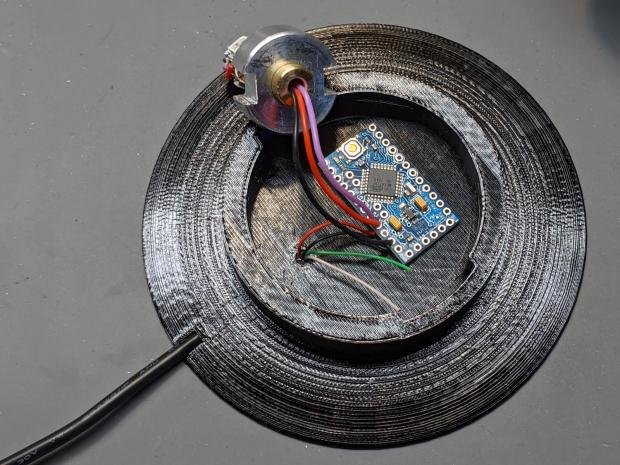
Nissan Fog Lamp – table mount interior It’s a knockoff Arduino Pro Mini without the USB interface found on a Nano, so the USB data wires don’t connect to anything.
The base might look better under a layer of (black?) epoxy, although I’m definitely a fan of those brutalist 3D printed striations.
The OpenSCAD source code as a GitHub Gist:
This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters. Learn more about bidirectional Unicode characters// Nissan Fog Light Base // Ed Nisley KE4ZNU 2020-04-20 /* [Hidden] */ ThreadThick = 0.25; ThreadWidth = 0.40; HoleWindage = 0.2; function IntegerMultiple(Size,Unit) = Unit * ceil(Size / Unit); Protrusion = 0.1; // make holes end cleanly //———————- // Dimensions ID = 0; OD = 1; LENGTH = 2; /* [Fog Light] */ ShellBase = [49.0,55.0,10.0]; Dog = [55.0,60.0,7.0]; DogWidth = 21.0; DogAngle = atan(DogWidth / ShellBase[ID]); echo(str("Dog angle: ",DogAngle)); ReflectorOD = 90.0; LensOD = 110.0; LensAngle = -90; // peak relative to dogs WallThick = 4.0; BaseThick = 2*WallThick; CableOD = 3.5; $fn = 3*4*5; //——————- // Useful shapes module Dogs(h=Dog[LENGTH]) { translate([0,0,h/2]) intersection() { cube([Dog[OD],DogWidth,h],center=true); cylinder(d=Dog[OD],h=h,center=true); } } //——————- // Build it difference() { union() { cylinder(d=(Dog[OD] + 2*WallThick),h=(BaseThick + ShellBase[LENGTH])); intersection() { resize([0,0,2*BaseThick]) sphere(d=LensOD); translate([0,0,BaseThick/2]) cube([2*LensOD,2*ReflectorOD,BaseThick],center=true); } } translate([0,0,BaseThick]) cylinder(d=ShellBase[OD],h=ShellBase[LENGTH] + Protrusion); translate([0,0,BaseThick]) { Dogs(); rotate(1.5*DogAngle) Dogs(); rotate(2*DogAngle) Dogs(2*ShellBase[LENGTH]); } rotate(LensAngle) translate([0.75*ShellBase[ID]/2,0,-Protrusion]) { cylinder(d=CableOD,h=2*BaseThick,$fn=8); translate([LensOD/2,0,CableOD/2]) cube([LensOD,CableOD,CableOD + Protrusion],center=true); } translate([31,0,ThreadThick-Protrusion]) cube([23.0,55.0,2*ThreadThick],center=true); } linear_extrude(height=2*ThreadWidth + Protrusion) { translate([32,0,-Protrusion]) rotate(-90) mirror([1,0,0]) text(text="Ed Nisley",size=6,font="Arial:style:Bold",halign="center"); translate([23,0,-Protrusion]) rotate(-90) mirror([1,0,0]) text(text="softsolder.com",size=5,font="Arial:style:Bold",halign="center"); }
-
Subscribe
Subscribed
Have a WordPress.com account? Log in now.

